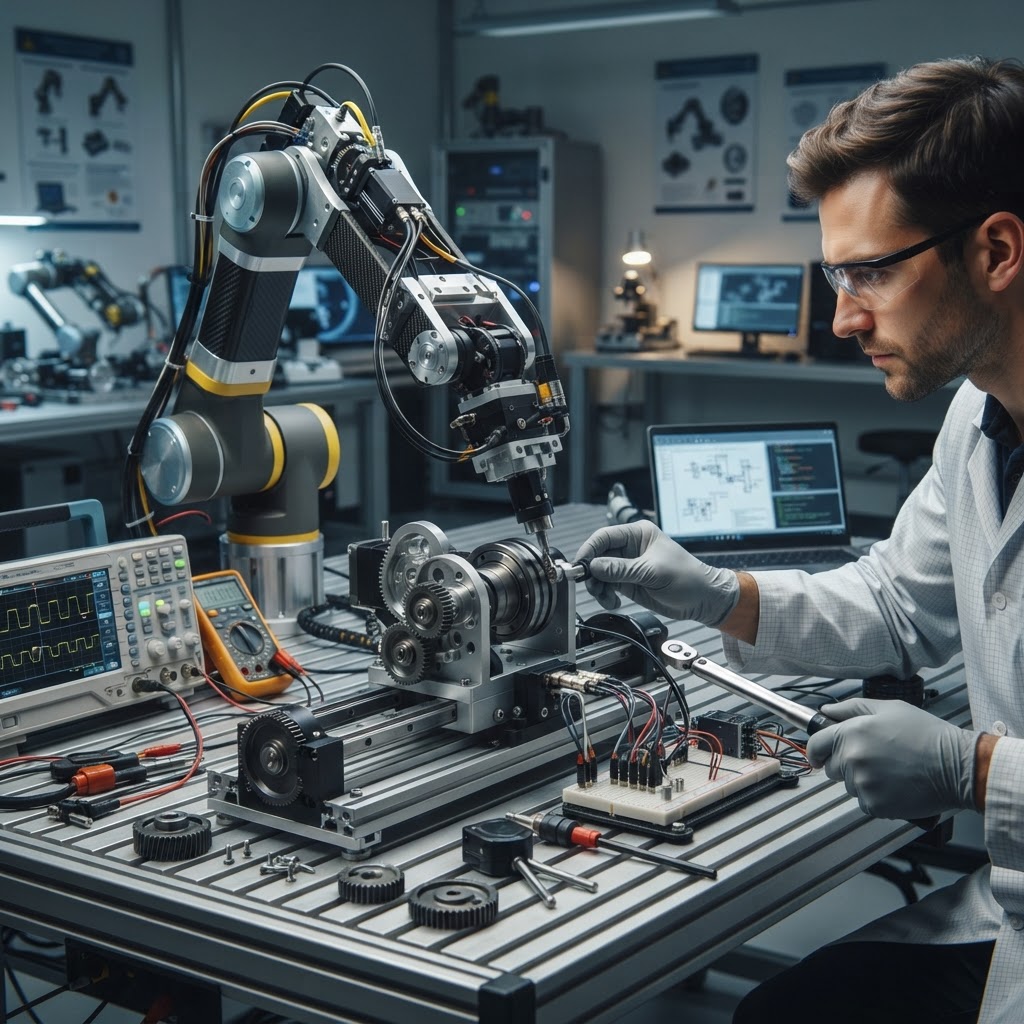
Interfacing Mechanical Structures
Designing sturdy frames to house electronic components.
Structural Integrity
Mechatronics is not just about code and circuits; it is also about physical form. The chassis of a robot must be light enough to be efficient but strong enough to protect internal wiring and components. Materials like aluminum, carbon fiber, or 3D-printed plastics are commonly used to create frames that can withstand the stresses of everyday operation.
Component Mounting
How you mount your sensors and actuators matters. Vibrations can cause sensor noise, which ruins your data, while loose motor mounts can lead to mechanical failure. Using dampeners and rigid mounting points ensures that your actuators deliver motion exactly where it is needed without shaking the rest of your system to pieces.
Wire Management and Modular Design
Proper cabling is often overlooked by beginners. A cluttered robot is hard to debug. Using zip ties, cable channels, and modular connectors makes your life much easier when something inevitably breaks. Design your structure with serviceability in mind so that you can swap out a battery or a motor without dismantling the entire chassis. This modular philosophy is a hallmark of professional engineering.
Try this at home
Design and build a cardboard 'chassis' for a smartphone. The goal is to create a holder that keeps the phone steady when placed on a vibrating surface, like the top of a washing machine. Experiment with different shapes: a cube, a pyramid, or a wider base. Use paper clips to stabilize joints. By observing which structure vibrates the least, you are performing a basic mechanical engineering stress test to see how geometry affects the structural rigidity of your electronic housing.