 Translate
HomeChallenge
Challenges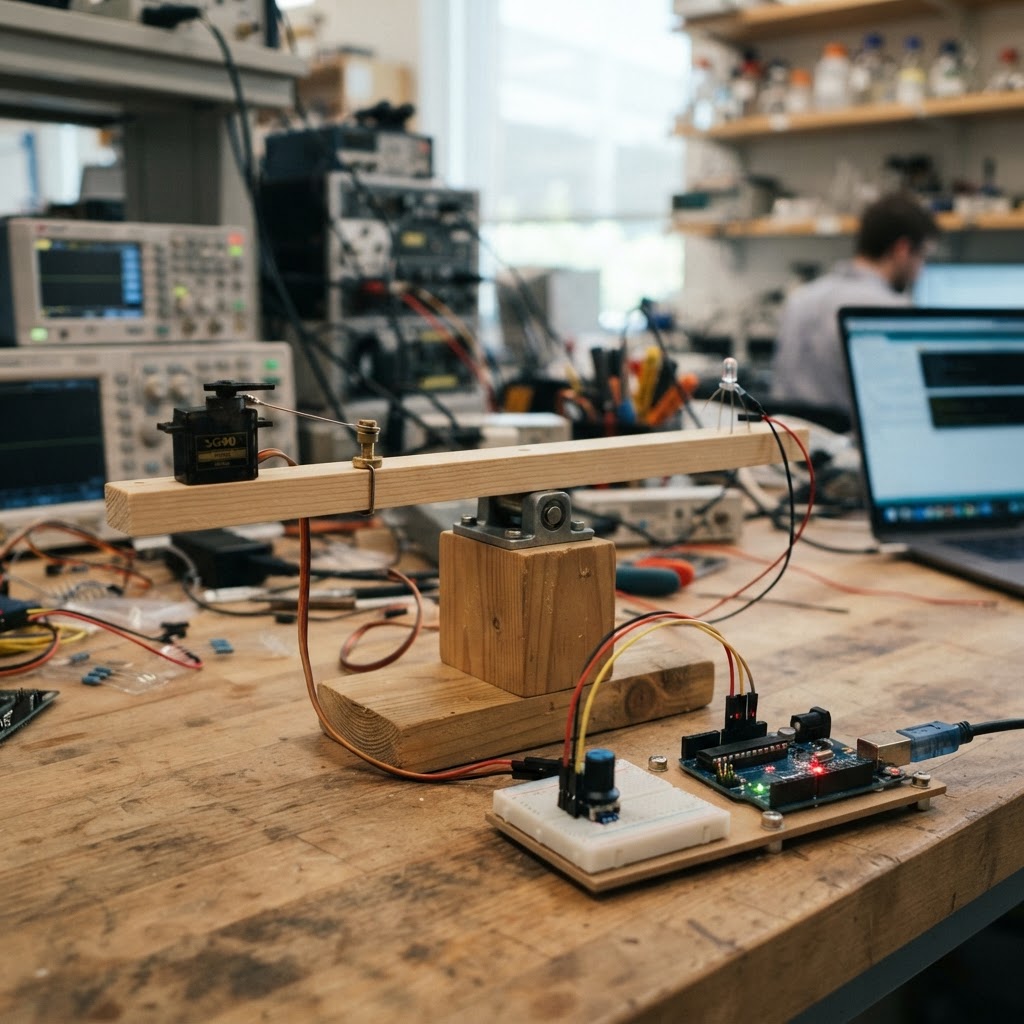
Controlhard
Haptic Feedback PID Precision Balancing
Design a closed-loop control system that stabilizes a weighted beam using a single servo actuator while providing real-time haptic resistance to the user. Implement a PID control algorithm to maintain the beam's center of gravity despite external perturbations, tuning the derivative gain to minimize oscillatory dampening. The system must process sensor input and provide active tactile force feedback to the operator's hand.
Materials: Microcontroller with PWM capability, rotary potentiometer, hobby servo motor, rigid cardboard or wood beam, assorted weights, rubber bands, and USB power source.
Deadline: October 7, 2026
Add to Google Calendar