HomeChallenge
Challenges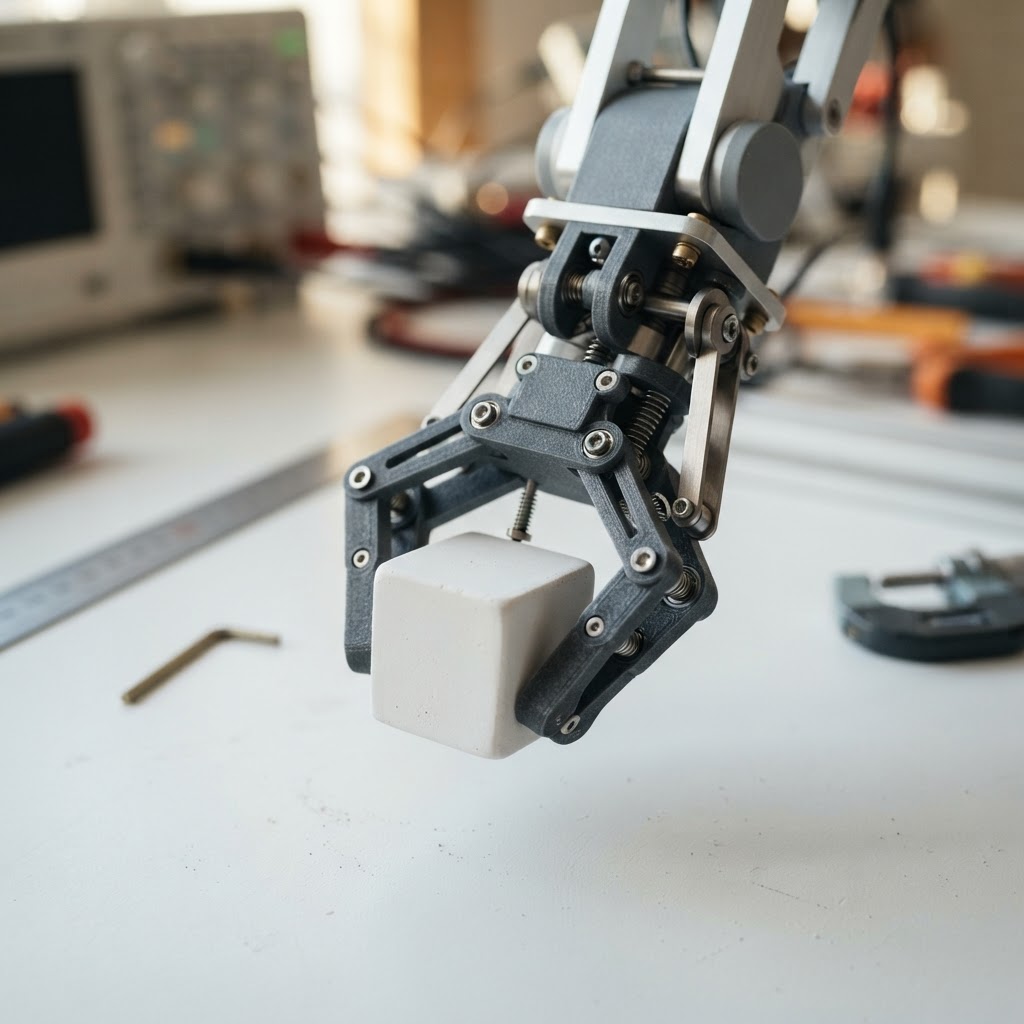
MechEhard
Kinematic Constraint Analysis: The Passive Gripper Challenge
Design and construct a purely mechanical, passive-actuation end effector capable of grasping three distinct objects of varying geometry and mass using only gravity or a single linear displacement input. Your solution must demonstrate a clear grasp of underactuated linkage synthesis and force closure principles while maintaining a structural mass under 500 grams. Evaluated based on cycle reliability, grip stability under a 2G acceleration load, and the integration of a compliant transmission mechanism.
Materials: 3D printer filament, stiff steel wire, elastic rubber bands, cardboard scraps, hot glue, assorted fasteners, and a counterweight.
Deadline: September 16, 2026
Add to Google Calendar